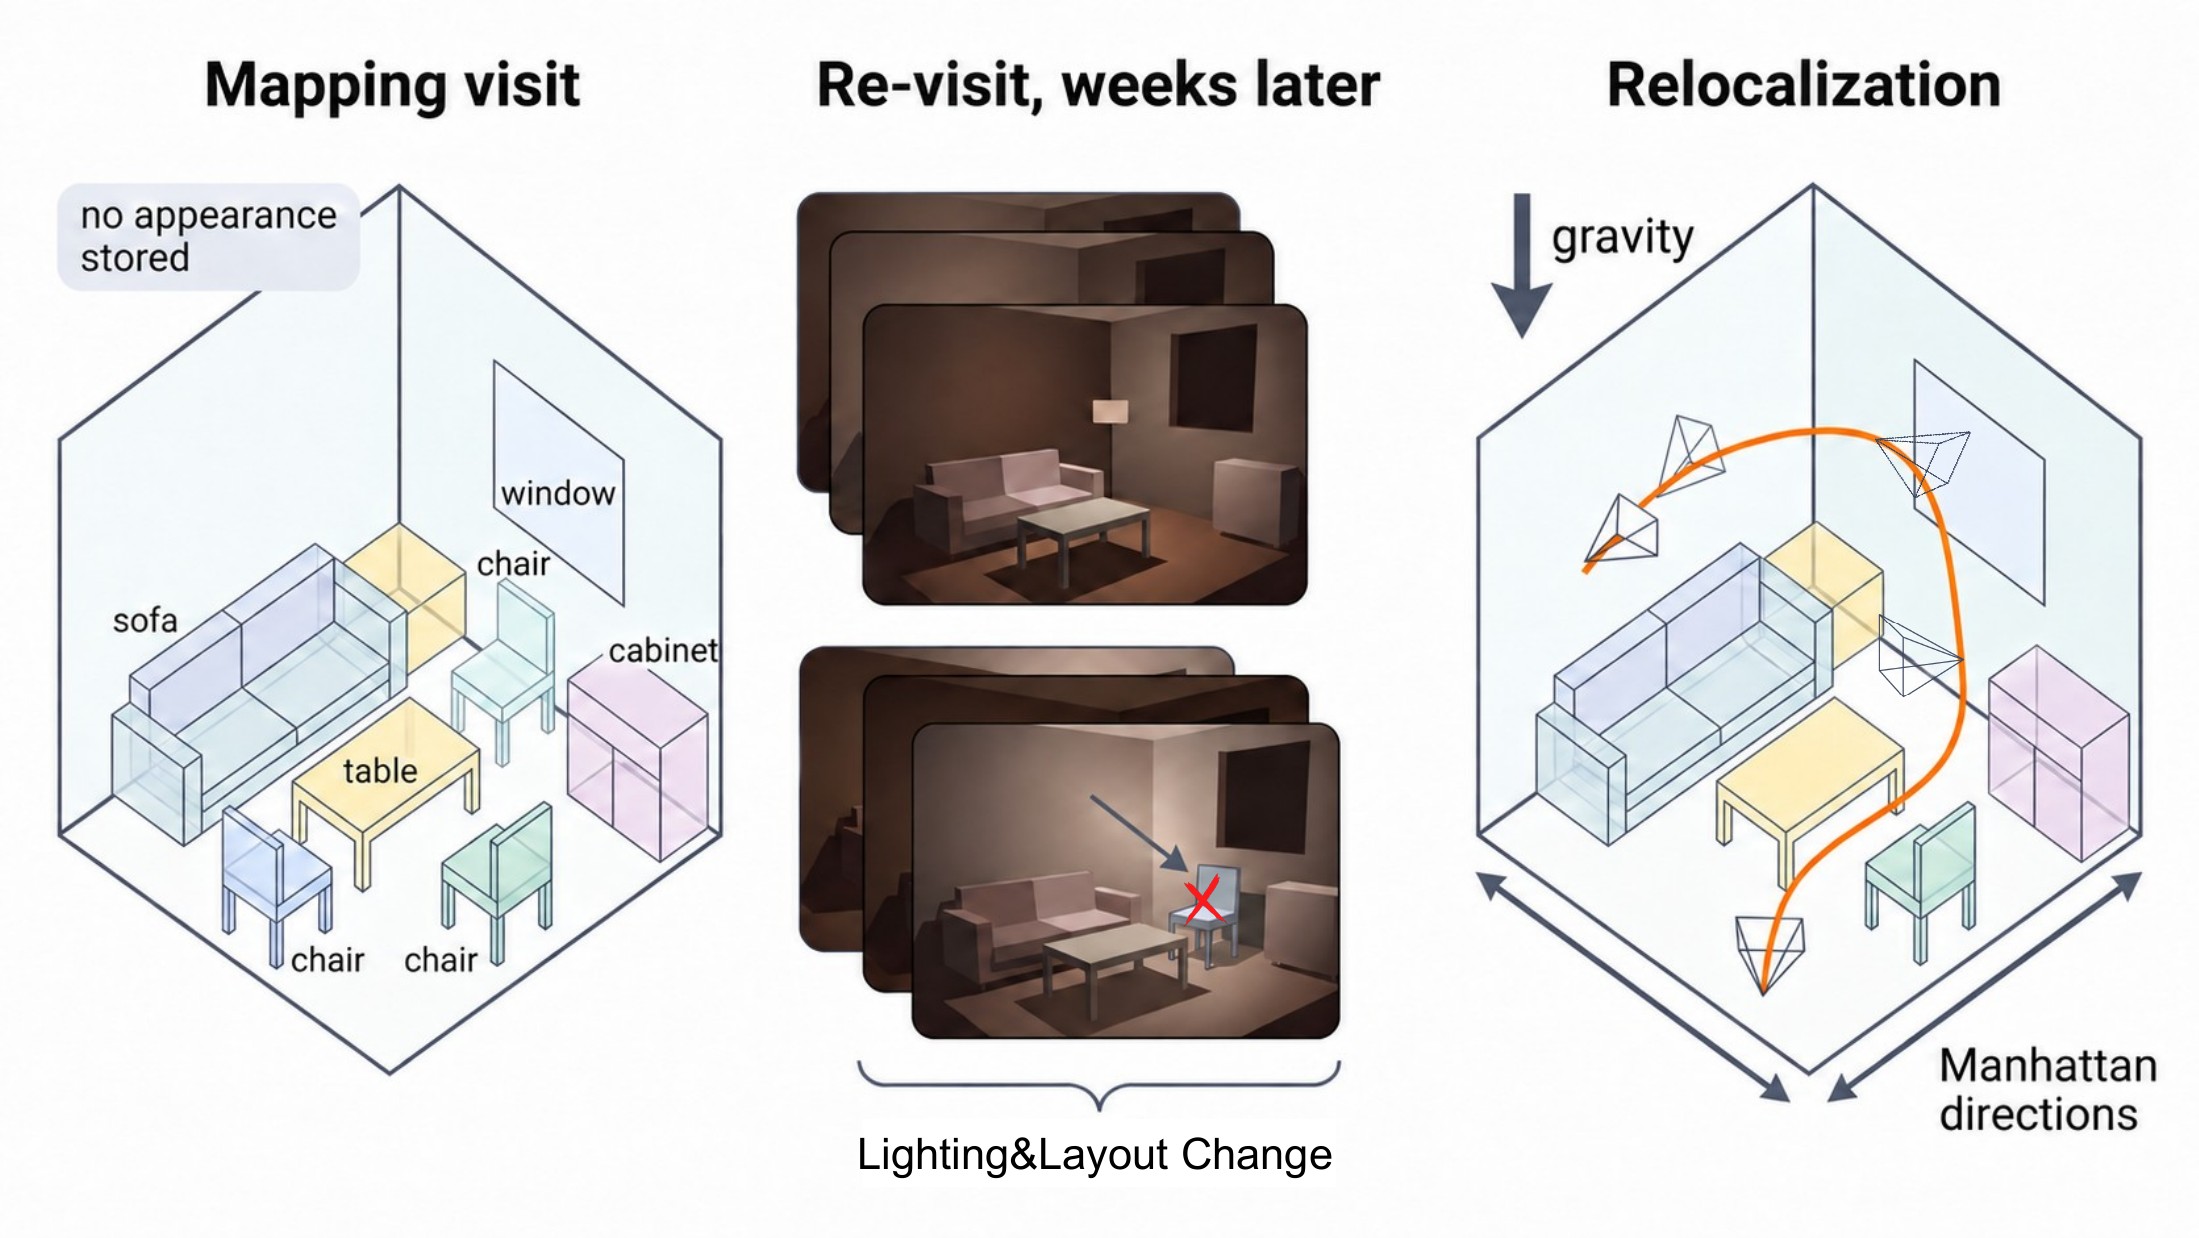
VideoReloc: Long-Term Indoor Video Relocalization against a Kilobyte-Scale Semantic Scene Graph
arXiv 2026
Relocalizing a camera after lighting and furniture changes using video context and a compact, 100 kB semantic map of 3D boxes.
I am writing my master’s thesis on long-term indoor relocalization at the TUM Chair of Computer Vision & Artificial Intelligence (Prof. Daniel Cremers), in collaboration with Huawei’s Hilbert Research Center. My research focuses on 3D scene understanding, camera trajectory generation, visual relocalization, and generative modeling.
Previously, I was a research intern at the TUM Visual Computing & Artificial Intelligence Lab (Prof. Matthias Nießner). My academic background is in Robotics, Cognition, Intelligence at the Technical University of Munich and Automation at Southeast University.
* Equal contribution
Google Scholar
arXiv 2026
Relocalizing a camera after lighting and furniture changes using video context and a compact, 100 kB semantic map of 3D boxes.
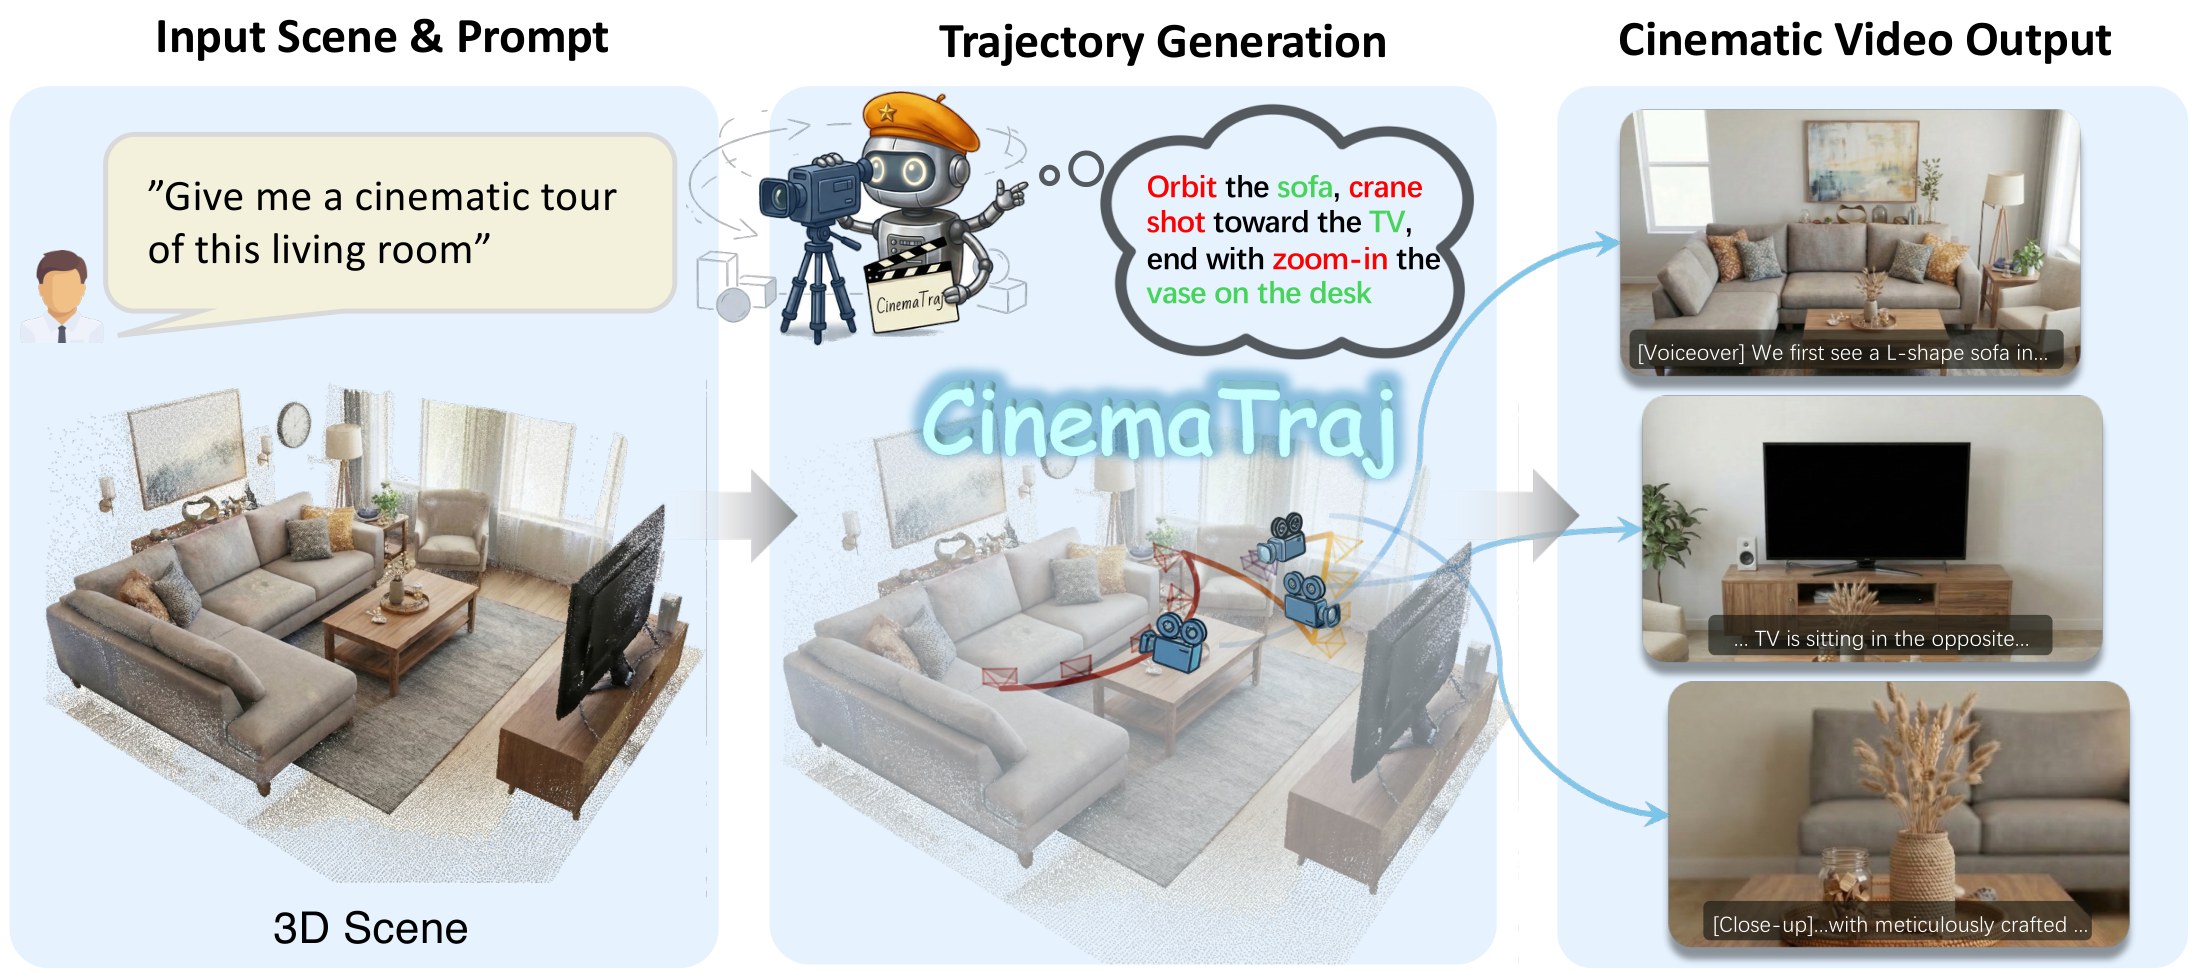
ACM MM 2026
Generating cinematic tours of 3D scenes from natural language, with spatially grounded camera movements and collision-aware trajectory planning.
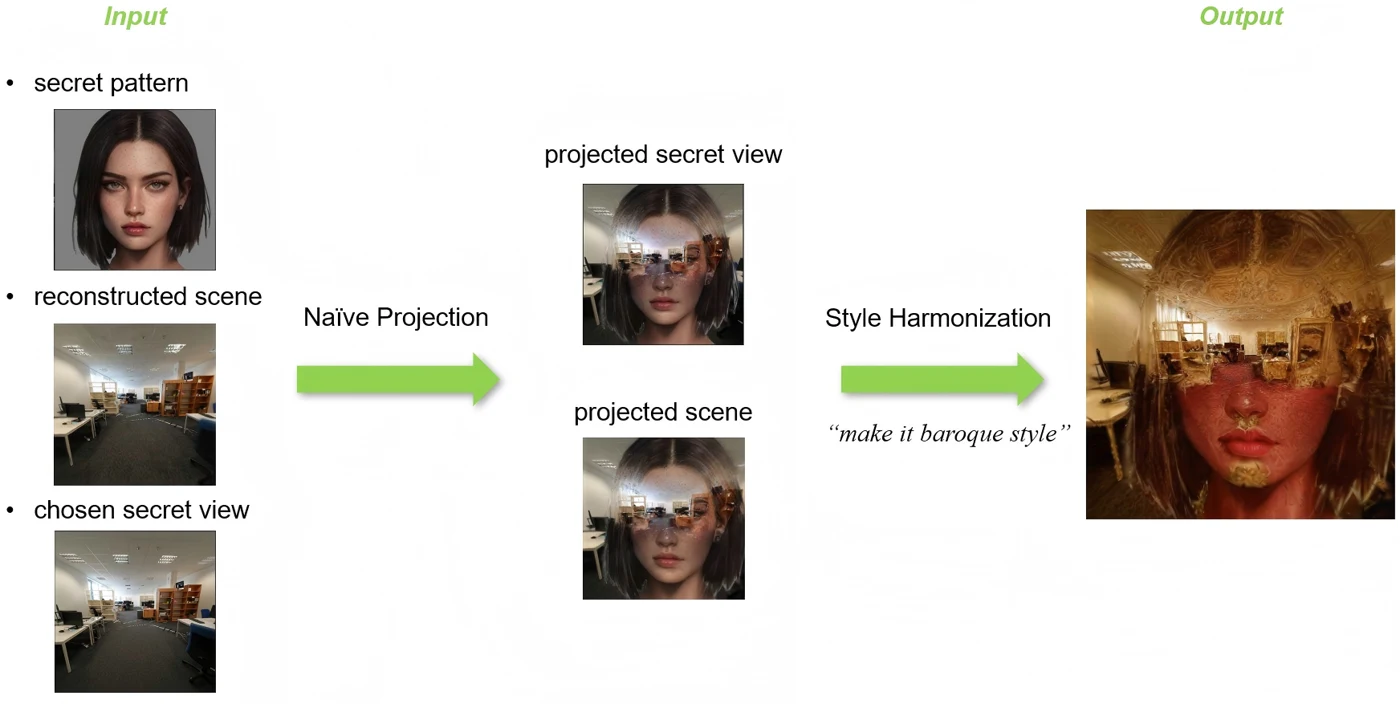
TUM Guided Research 2025
Embedding a chosen pattern into 3D Gaussian scenes so it becomes legible from a designated viewpoint, with diffusion-guided editing to harmonize the scene’s appearance.
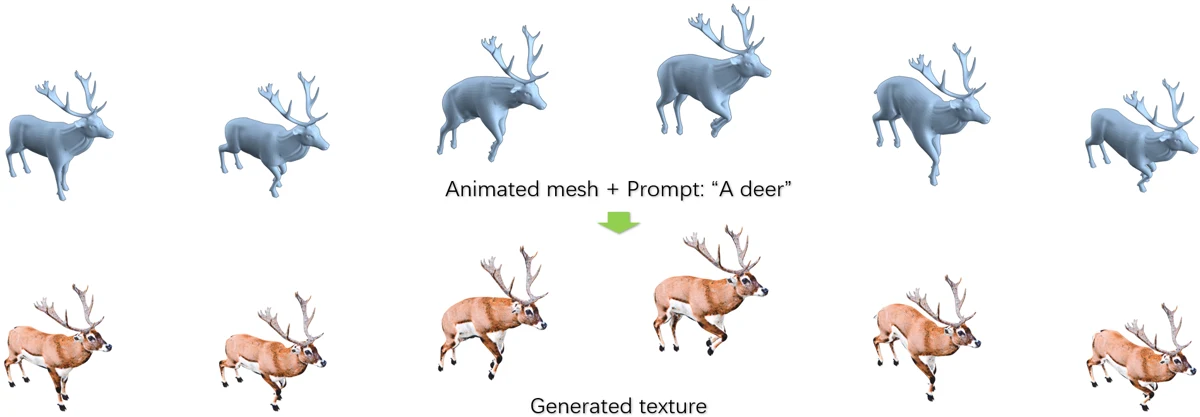
4D Generation
Generating textures for animated 3D objects using diffusion priors.
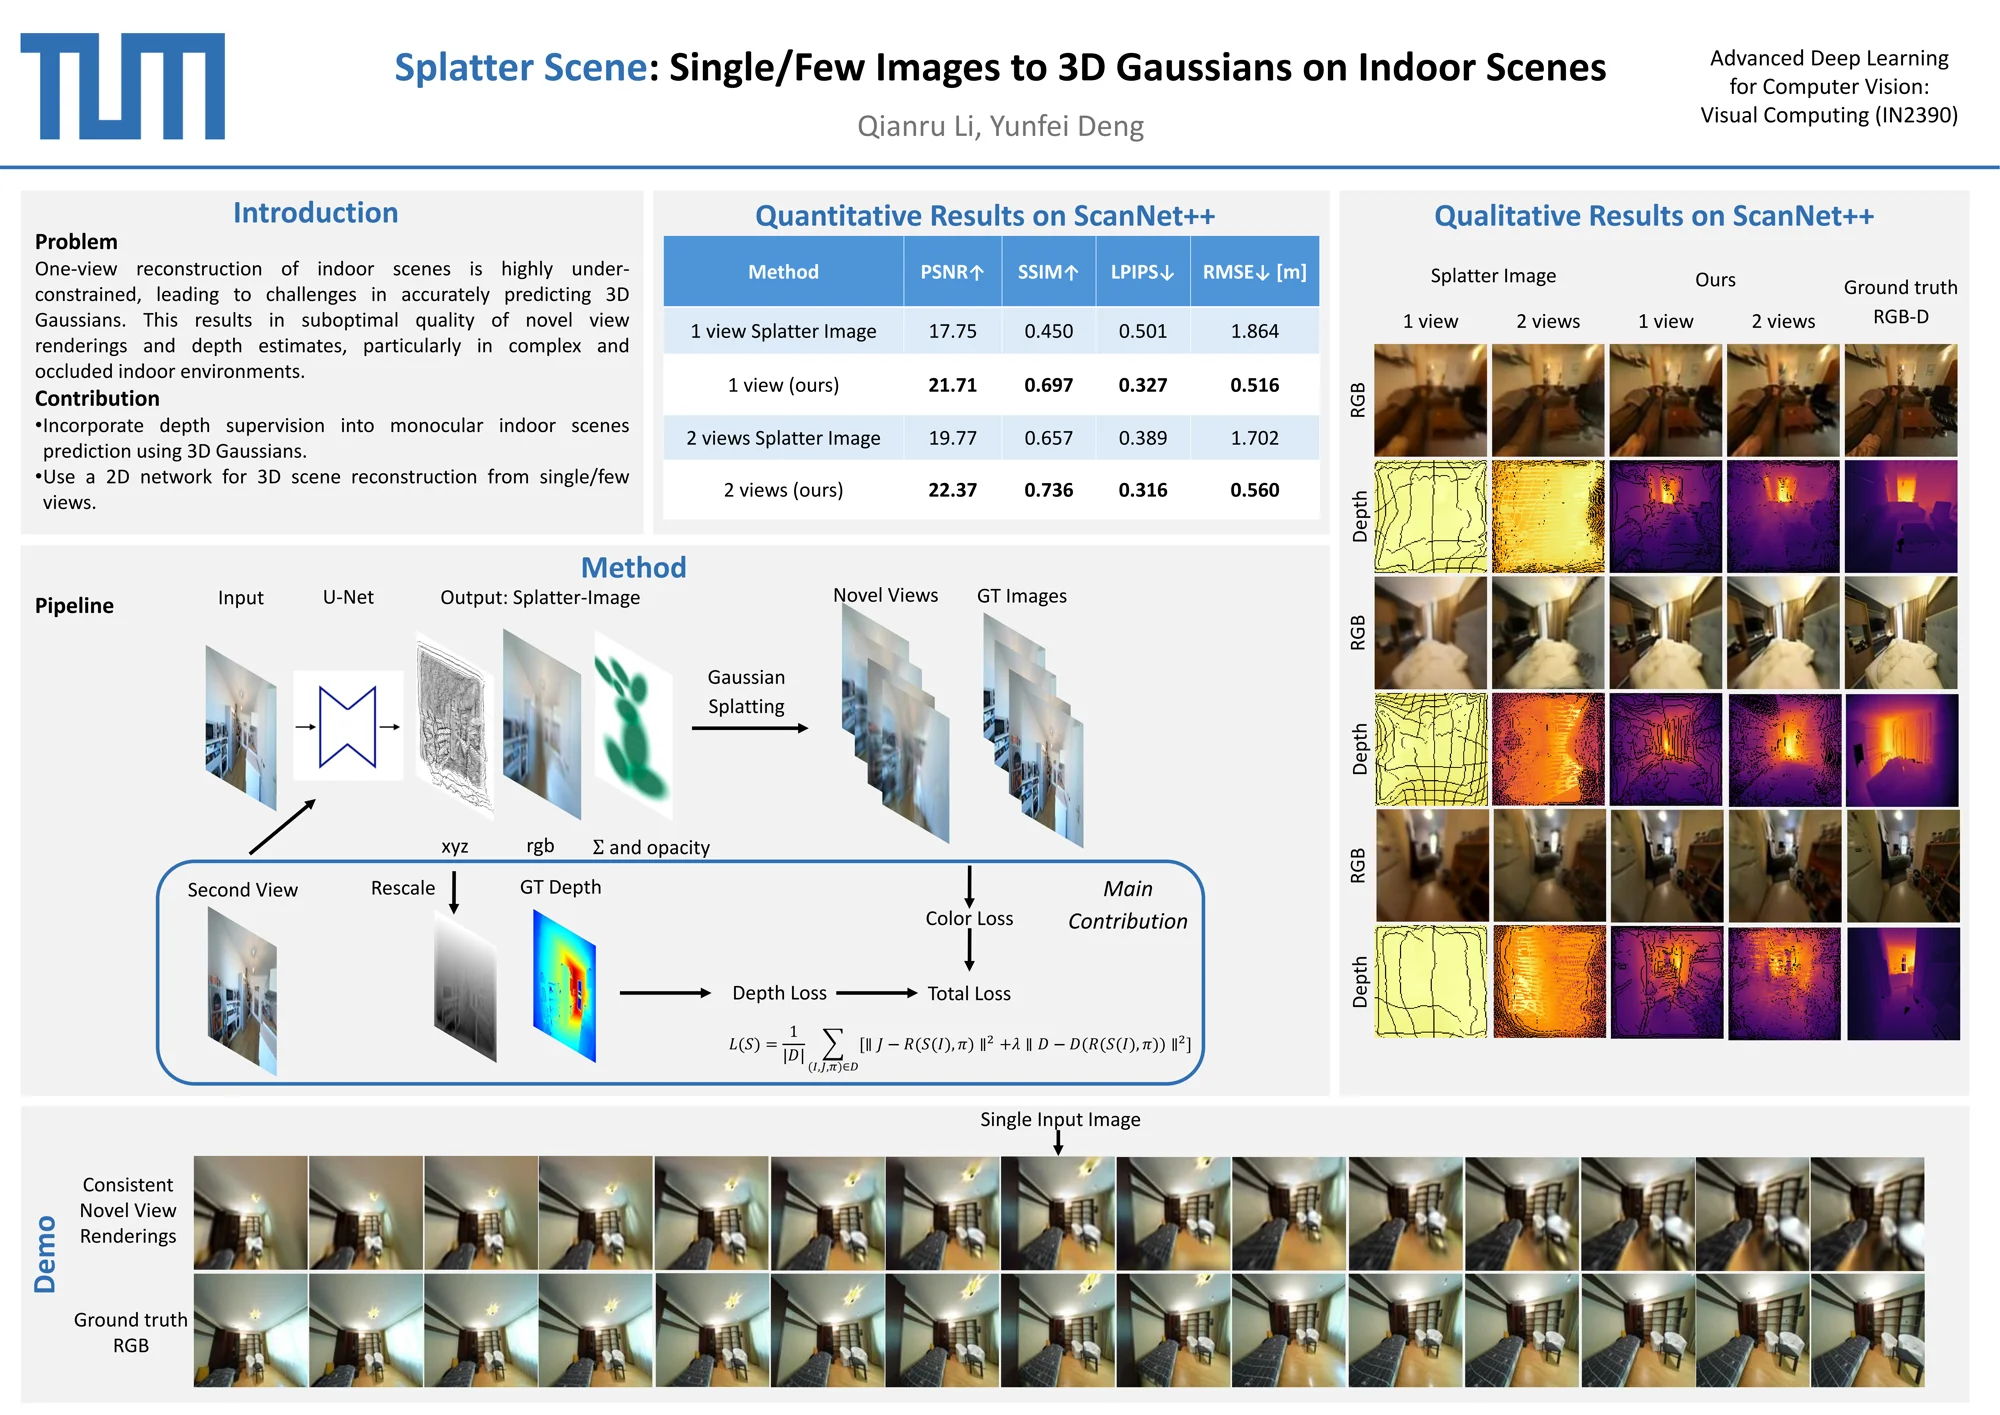
3D Reconstruction
Extending object-level Gaussian prediction to reconstruct indoor scenes from sparse views.
– Present

TUM Chair of Computer Vision & Artificial Intelligence (Prof. Daniel Cremers) · In collaboration with Huawei Hilbert Research Center
Long-Term Indoor Video Relocalization against a Kilobyte-Scale Semantic Scene Graph (VideoReloc)
–
Huawei · Hilbert Research Center, Munich
Cinematographic camera paths in 3D Gaussian Splatting, scene generation and texturing with diffusion priors, and physically plausible scene layout optimization.
–
TUM Visual Computing & Artificial Intelligence Lab (Prof. Matthias Nießner) · Part-time
Secret message embedding in 3D textures, 4D object texturing with diffusion priors, and feed-forward 3D scene generation from a single image.
–
Technical University of Munich
–

Southeast University
For PhD opportunities or research collaborations.